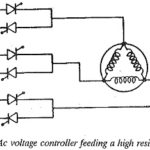
Control of AC Motors Torque Control
Control of AC Motors Torque Control: From the foregoing discussion for Control of AC Motors Torque Control it is clear that the motors used for textile applications must have high starting…
Uncompensated Large Time Constants: It is possible to compensate only one Uncompensated Large Time Constants using a PI controller. A PID controller is used to compensate for two large time…
Design of Controllers for Linearly Varying Inputs: The Design of Controllers for Linearly Varying Inputs discussed in the foregoing sections are for the step input. The performance has been found…
Methods of Compensation in Control System: The Different Methods of Compensation in Control System are Cascade Compensation Feedback Compensation Load Circuit Compensation Input Circuit Compensation A drive system having closed…
Control System Performance: From the foregoing discussion on control systems it can be seen that the beÂhaviour of the control systems can be specified, based on several time domain specifications.…
Root Locus Plot: In the electrical drives employing closed loop control techniques, it is often necessary to investigate the effects of changing the parameters of the system on its stability.…
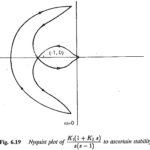
Nyquist Criterion: Nyquist Criterion - This stability criterion enables one to establish the stability of a system using a graphical procedure in the frequency domain. Here also there is no…
Routh Hurwitz Criterion: The Routh Hurwitz Criterion states that the system is stable if the Routh table has no negative elements in the first column. The roots of the characteristic…